Computer vision build log

Teaching a computer to see a 20px footbag.

Easy for you. Hard for a model. Drag the dial and watch it trade misses for false alarms.

Confidence threshold0.25
32of 33 footbags found
0false alarms
False alarms (the model saw a footbag in frames with none)
Held-out frames the model never trained on. 0.25 is the threshold the pipeline actually uses.
0how wide the sack is
0training rounds
0hand-checked labels
Progress

Four rounds. Pick one.
8labels. Found 3 of 4 test sacks. Not enough to trust.
180labels, found by the model itself. Found 4 of 4. First real touch logged.
5ground-level labels. Not enough. It still missed the test.
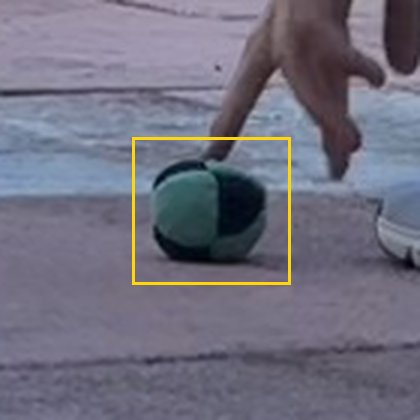
16ground-level labels. A sack it had never seen went from zero detections to a hit.
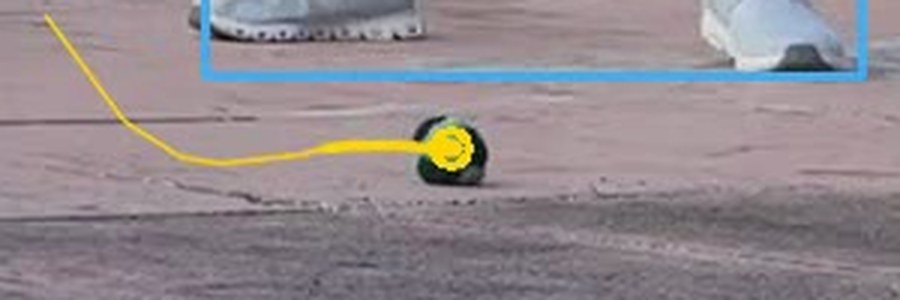
Oops

The bug that made a correct answer look wrong.

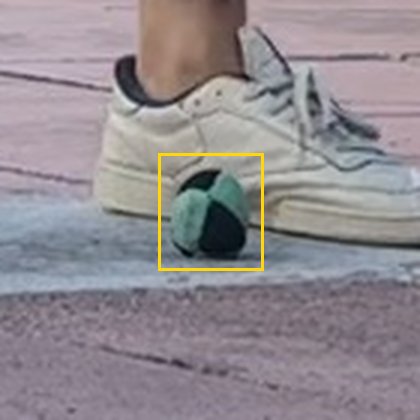
Close-up of a yellow tracker dot sitting on top of a real footbag on the pavement
That yellow dot is the detection. The real ball is hiding right under it. I once called a correct detection a false positive because the overlay covered the evidence, and almost reverted a good model. Check the raw frame.
Players

Three people. Thirty IDs.

Start
30
Smarter tracker
21
Higher res
33
Tighter NMS
19
P1P2P3P10P18P20P30

The real cause: a player behind fence bars went undetected for 10+ seconds. You can't re-ID someone you never saw.

Reality check

Does it keep score? Not yet.

30%
34%
35%
● sack seen● guessed through a gap● lost
0touches and drops counted on the 60s test clip. That doesn't mean zero happened. Nobody hand-scored it yet, so I can't say.